Real-time Trash Detection
Automated Waste Classification with YOLOv11 Computer Vision

Overview
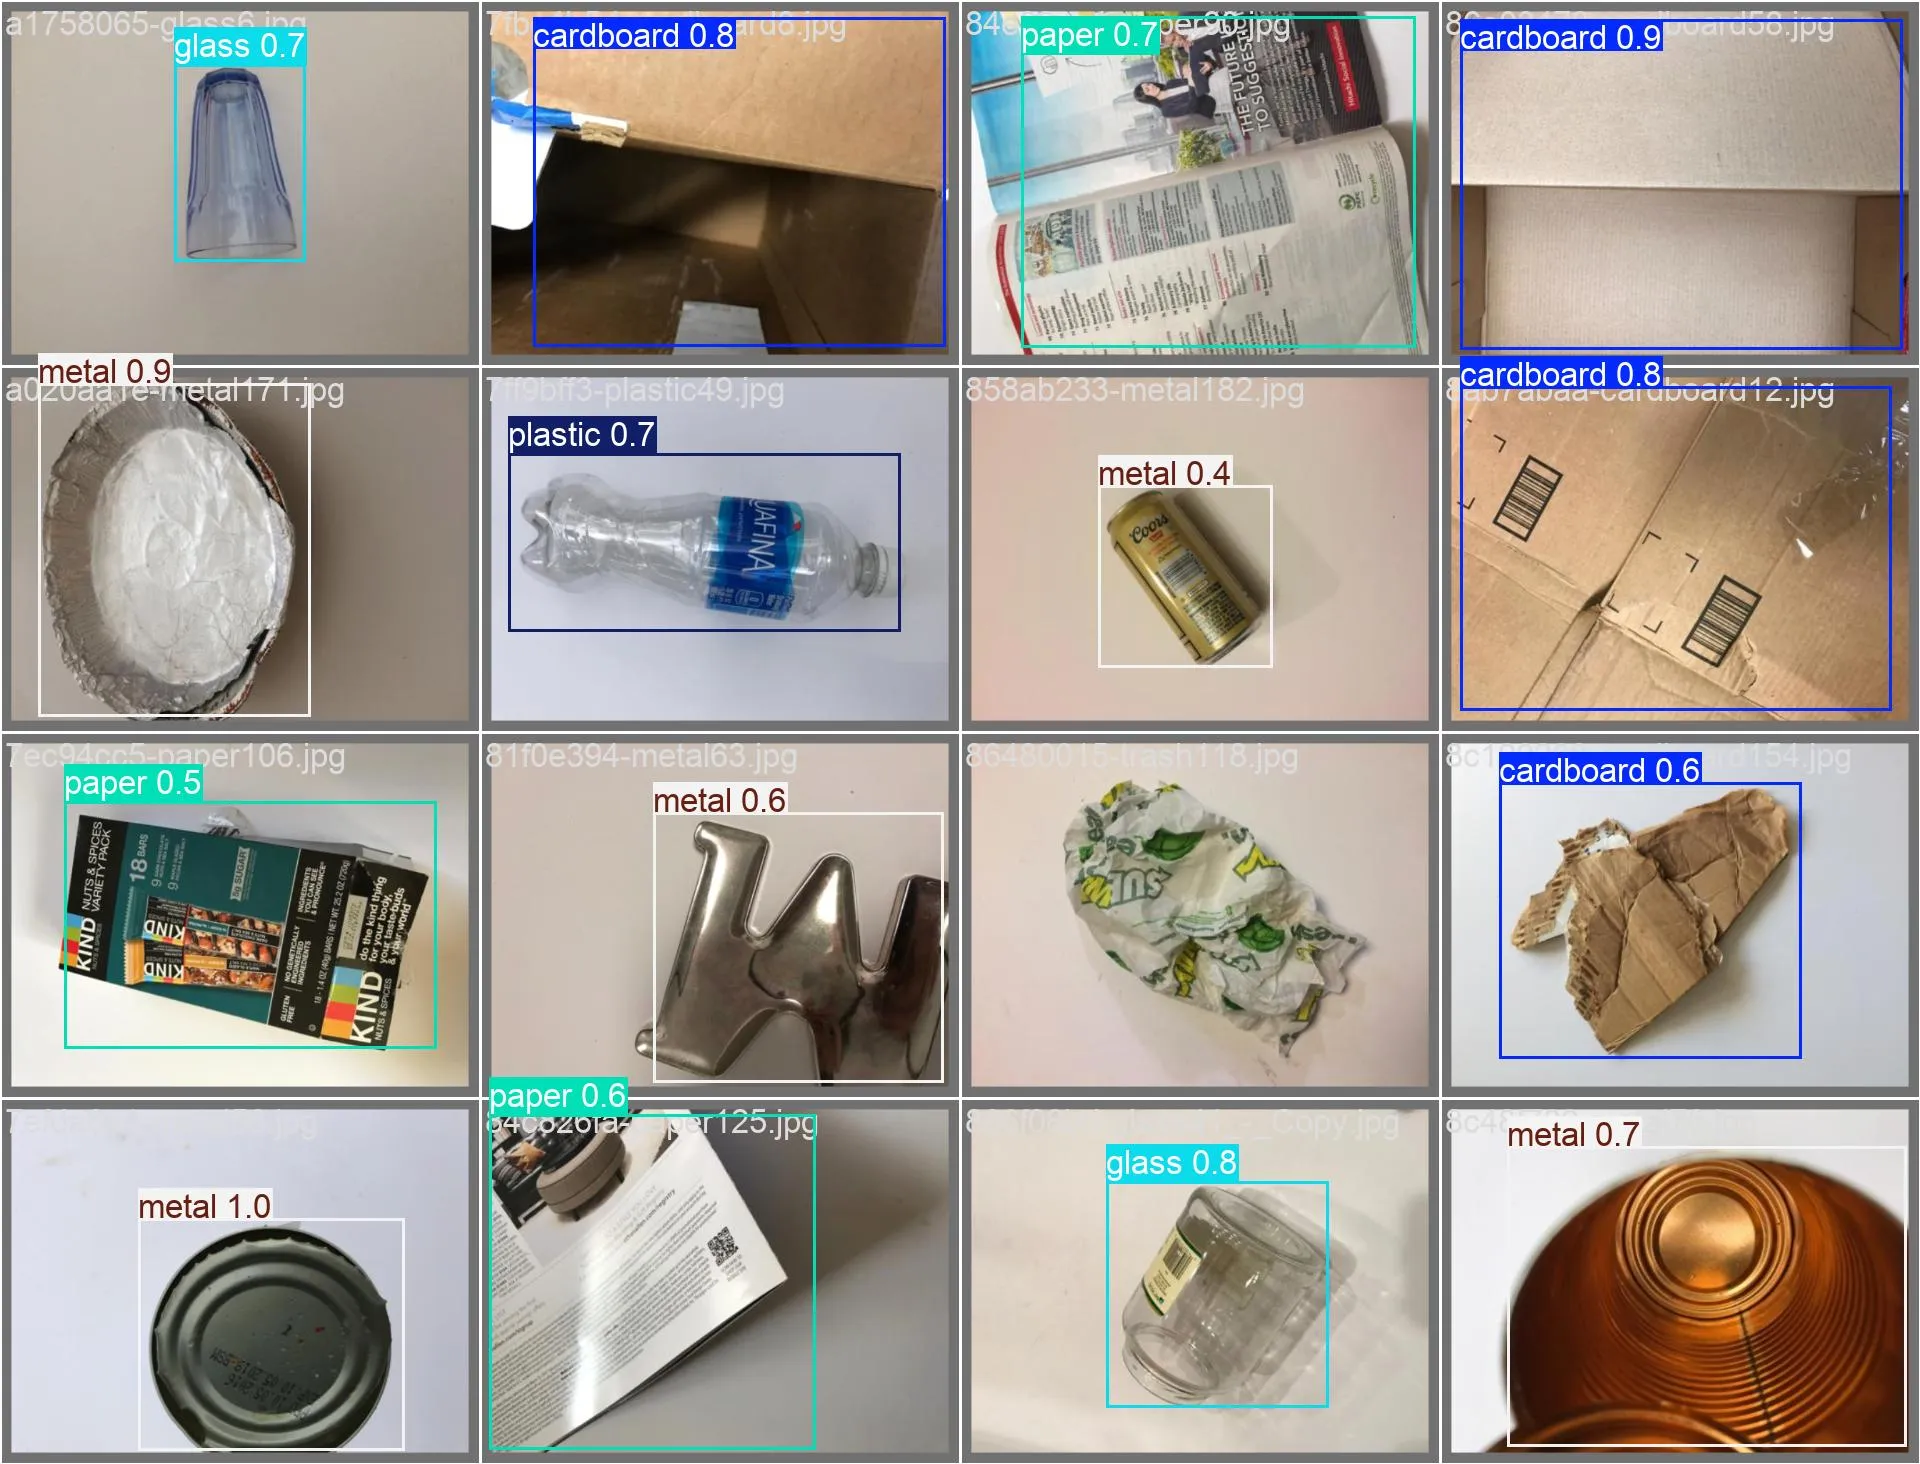
An automated vision system designed to identify and classify municipal solid waste into distinct categories (plastic, organic, paper, metal, glass) in real-time. Fine-tuned on specialized waste datasets to operate reliably under variable lighting and occlusions.
Introduction & Problem
Inadequate waste segregation at source poses a major global environmental challenge. Manual sorting is hazardous and inefficient. This project applies high-performance lightweight object detection models to empower automated sorting facilities and smart waste bins.
Tools & Technologies
State-of-the-art detector with enhanced feature pyramid representation.
Model training, hyperparameter tuning, and data augmentation pipelines.
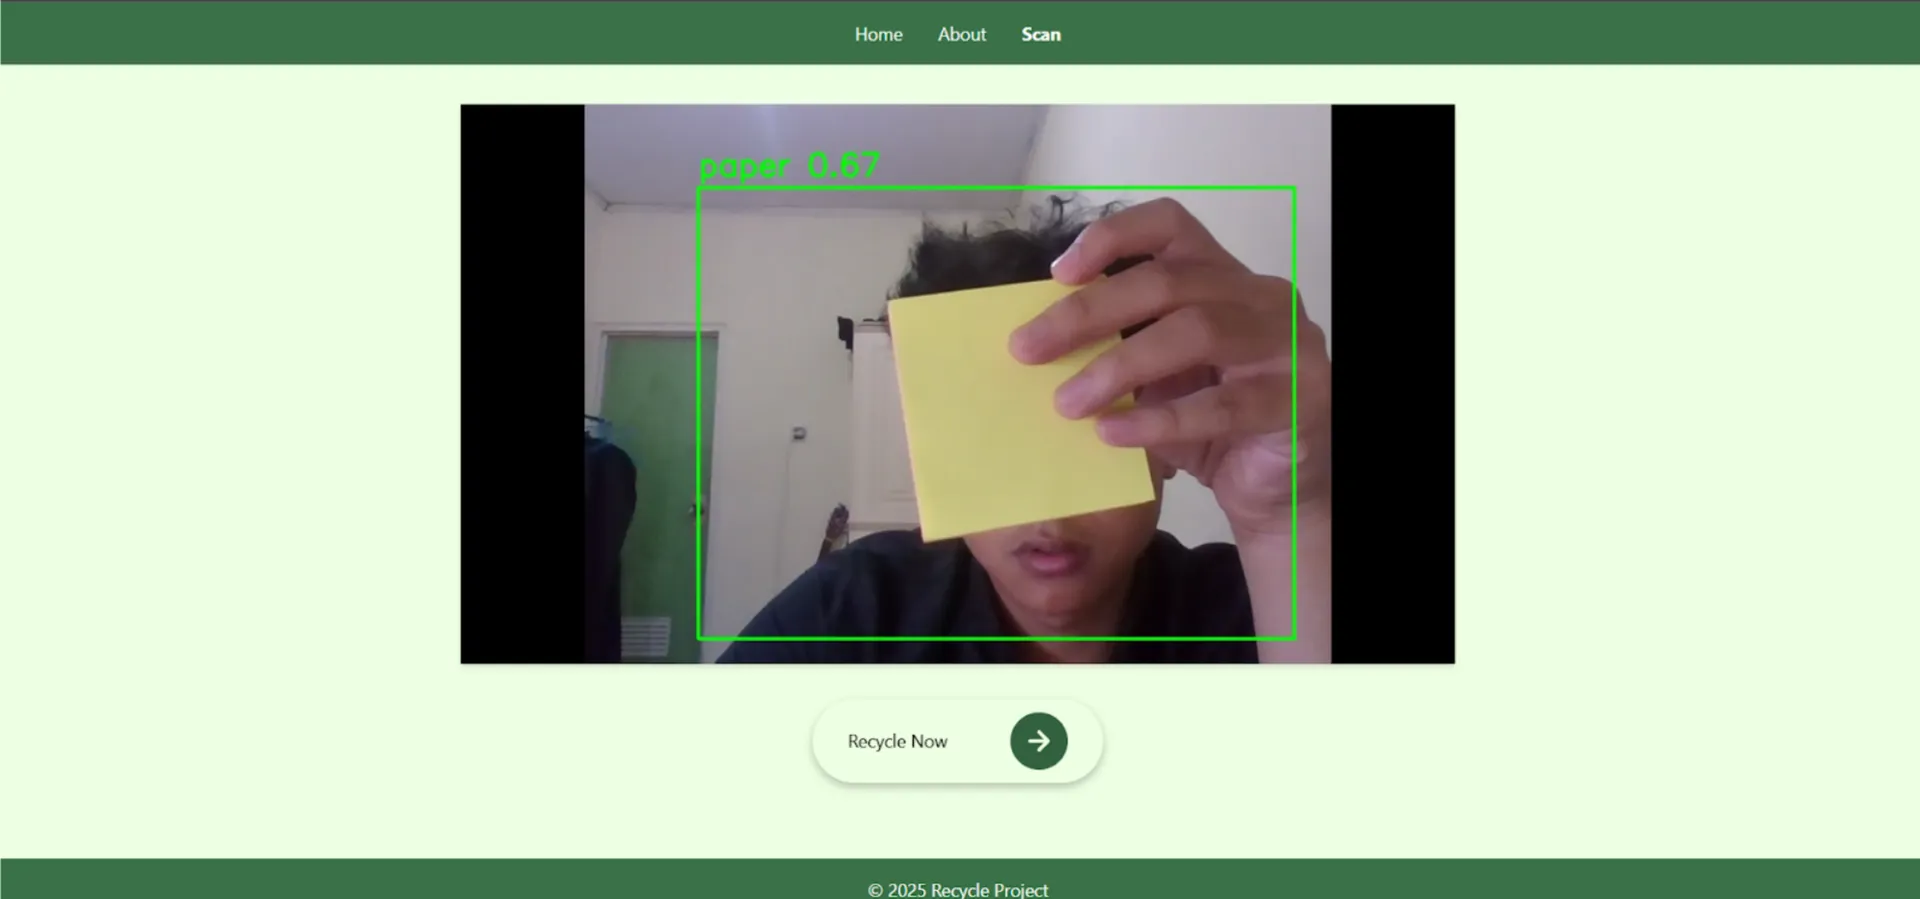
Camera stream capture, preprocessing, and real-time bounding box visualization.
Key Features & Architecture
Multi-Category Waste Classification
Accurately distinguishes diverse waste items across overlapping scenarios.
High-Speed Inference
Optimized for edge deployment on embedded vision hardware.
Robust under Occlusion
Trained with advanced Mosaic and MixUp augmentations to handle crumpled or partially hidden trash.
Results & Impact
Model Accuracy
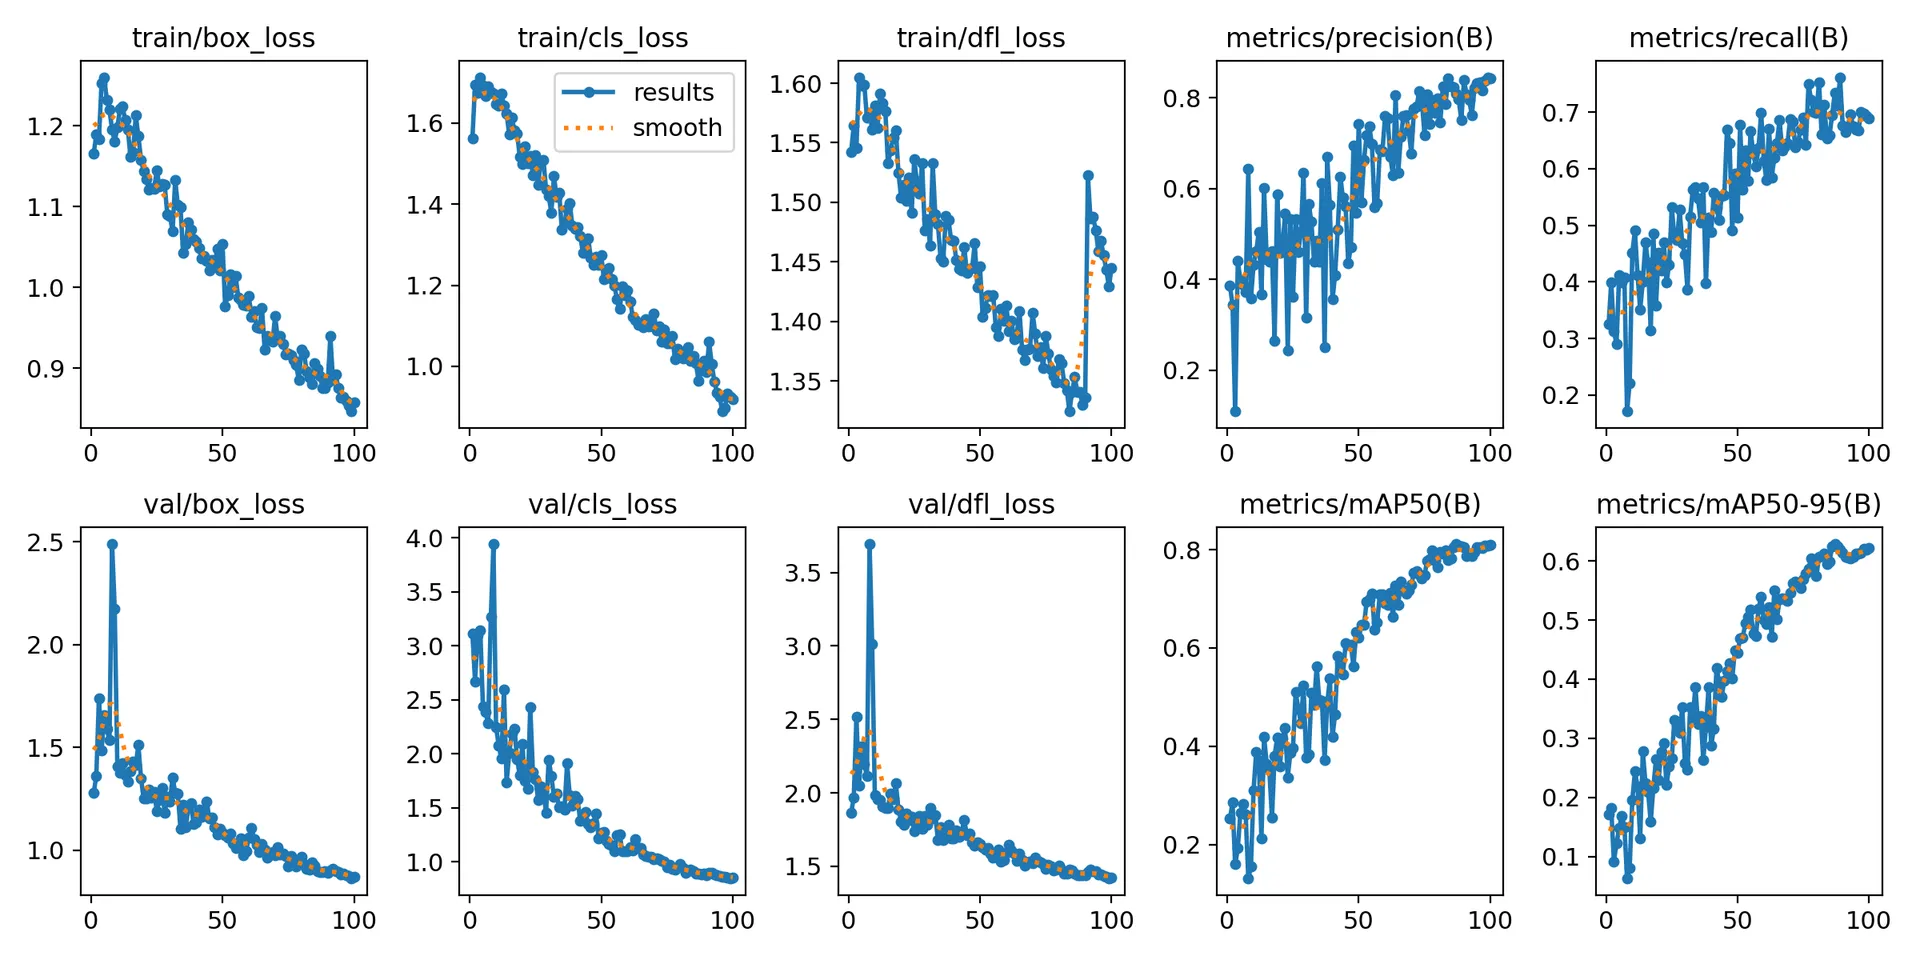
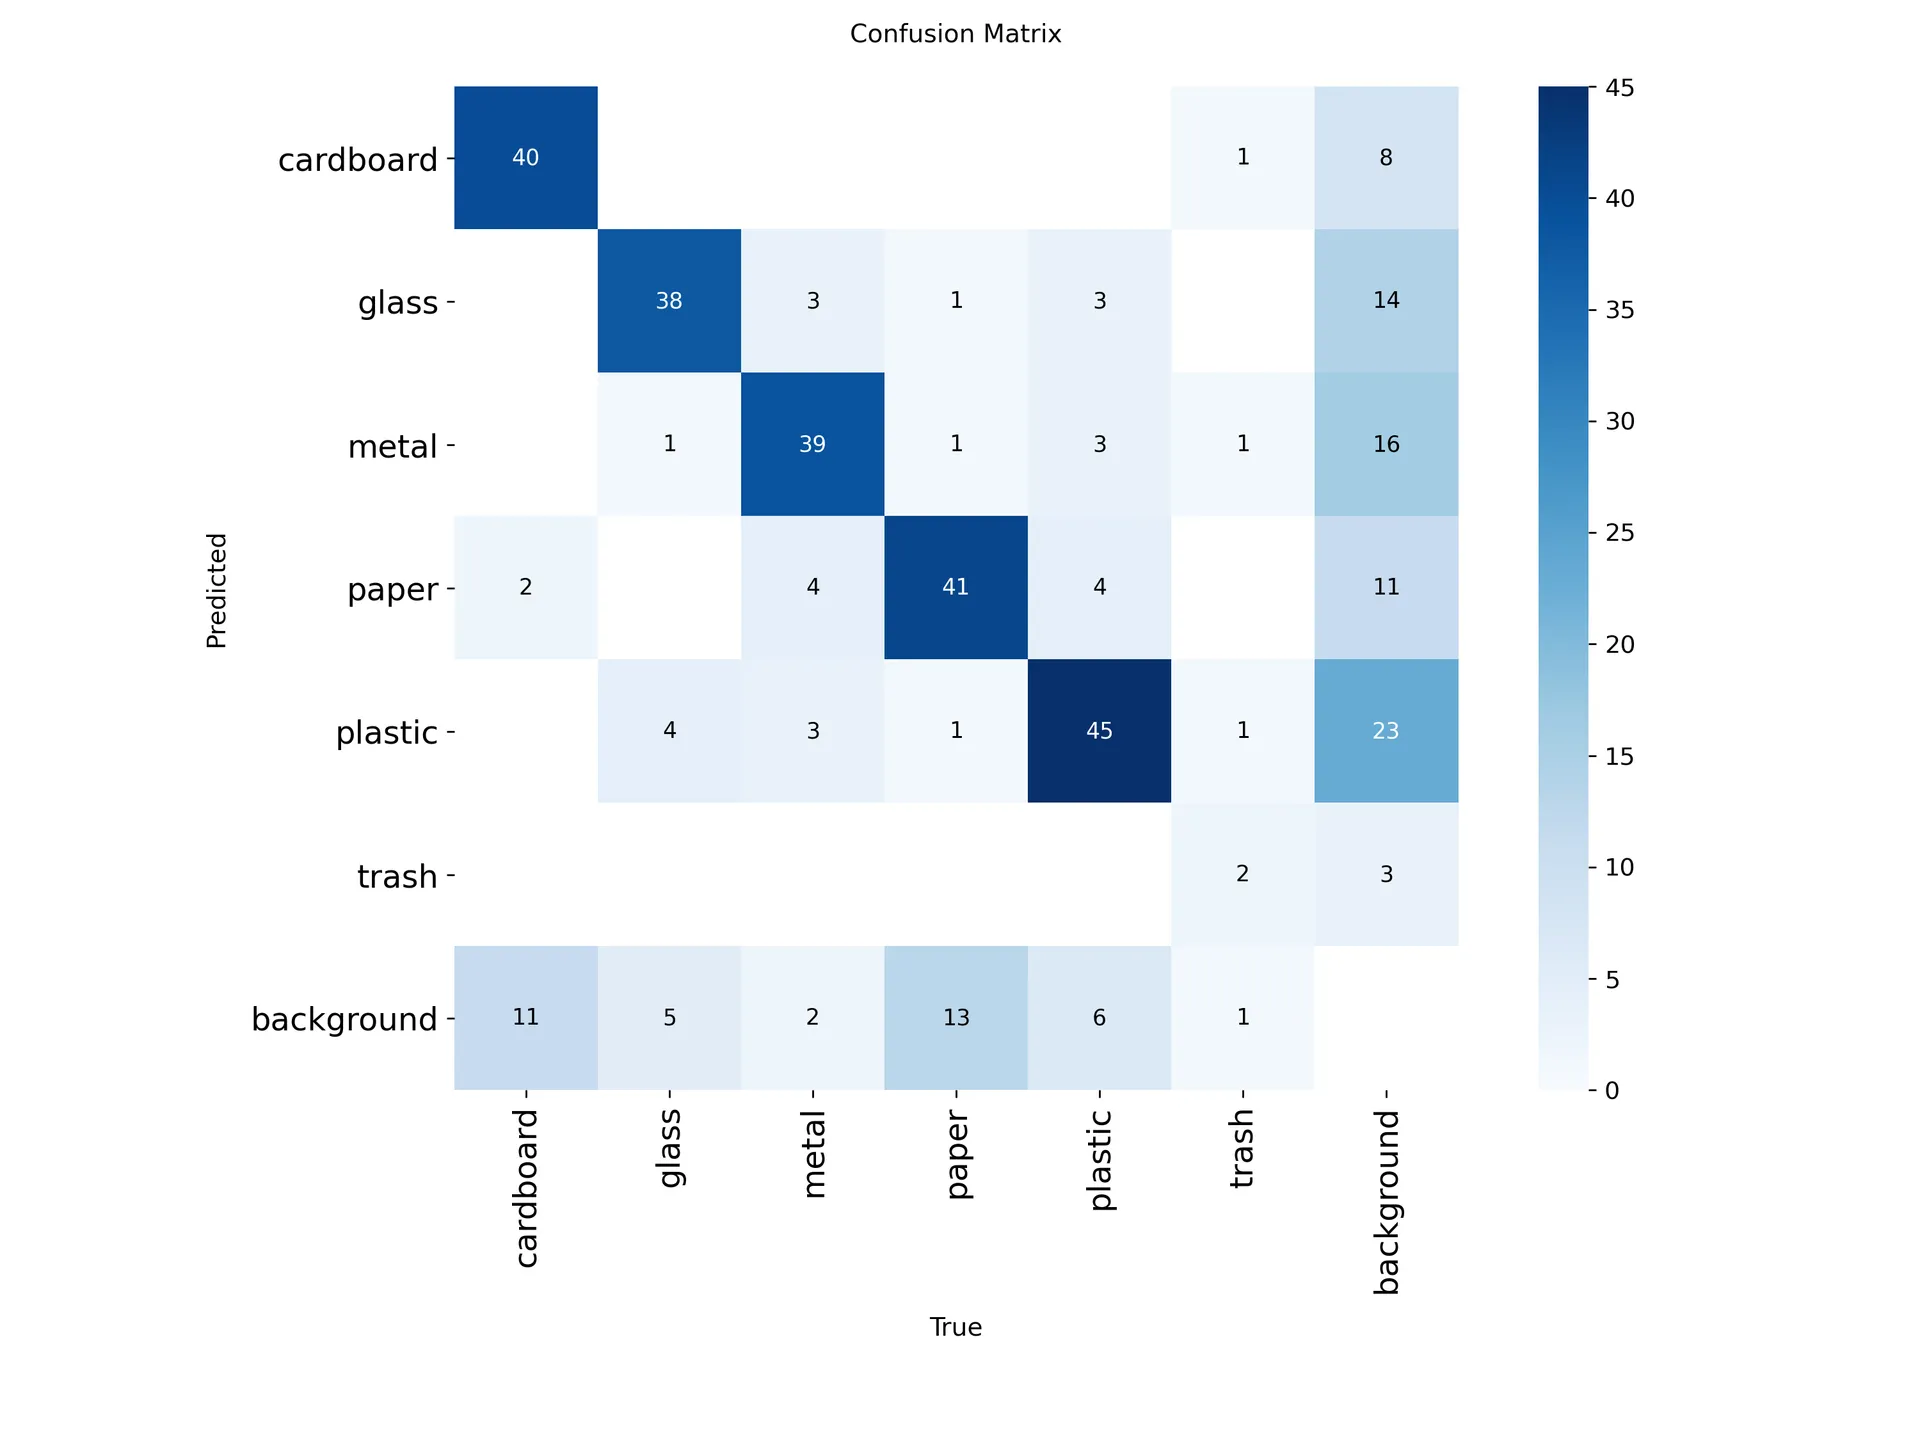
85.12% mAP@0.5
Mean Average Precision across all classes
Inference Speed
~60 FPS
Real-time processing capability
Classes
6+ Categories
Organic, Plastic, Paper, Metal, Glass, General
Project Gallery